Additional projects / Tools & mechanisms
Crab-leg robot mechanism
A puppet-like teaching leg and a servo-powered leg used to explore crawling movements.
Open the numbered review →Powered and teaching mechanisms
Photos 281, 283
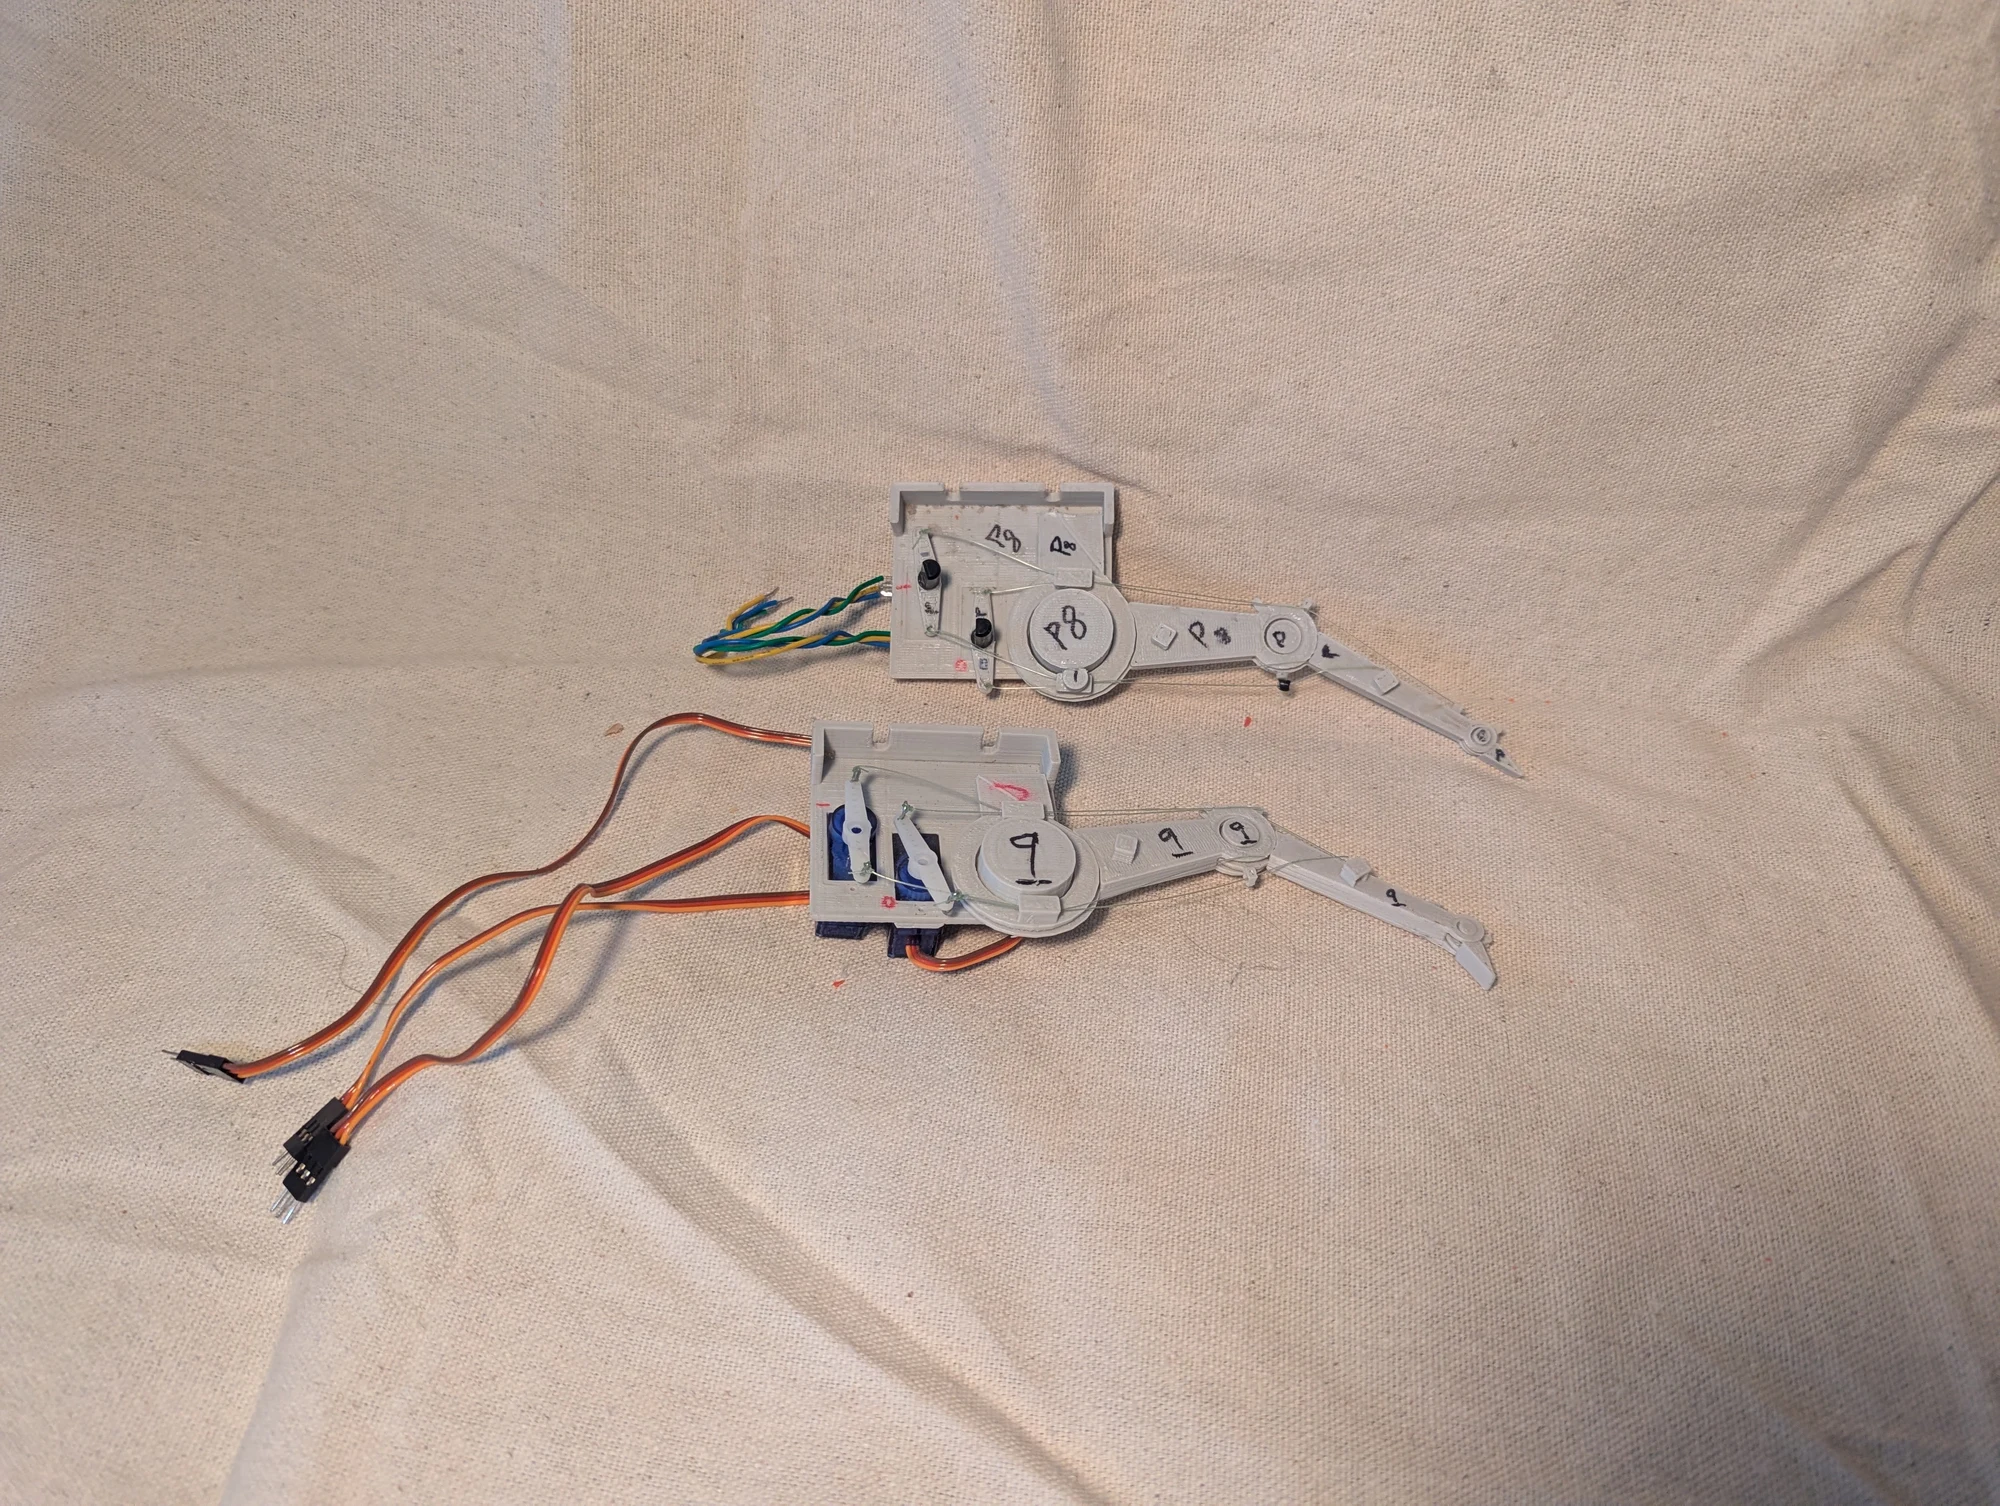
A crab-leg mechanism intended for an underwater crawling robot. Two servos pulled fishing lines attached to the joints. I moved a separate leg fitted with potentiometers, sensors that measure joint position, recorded those movements, and used them to guide the powered leg. It produced a crawling motion, but the mechanism was too delicate for an autonomous robot.
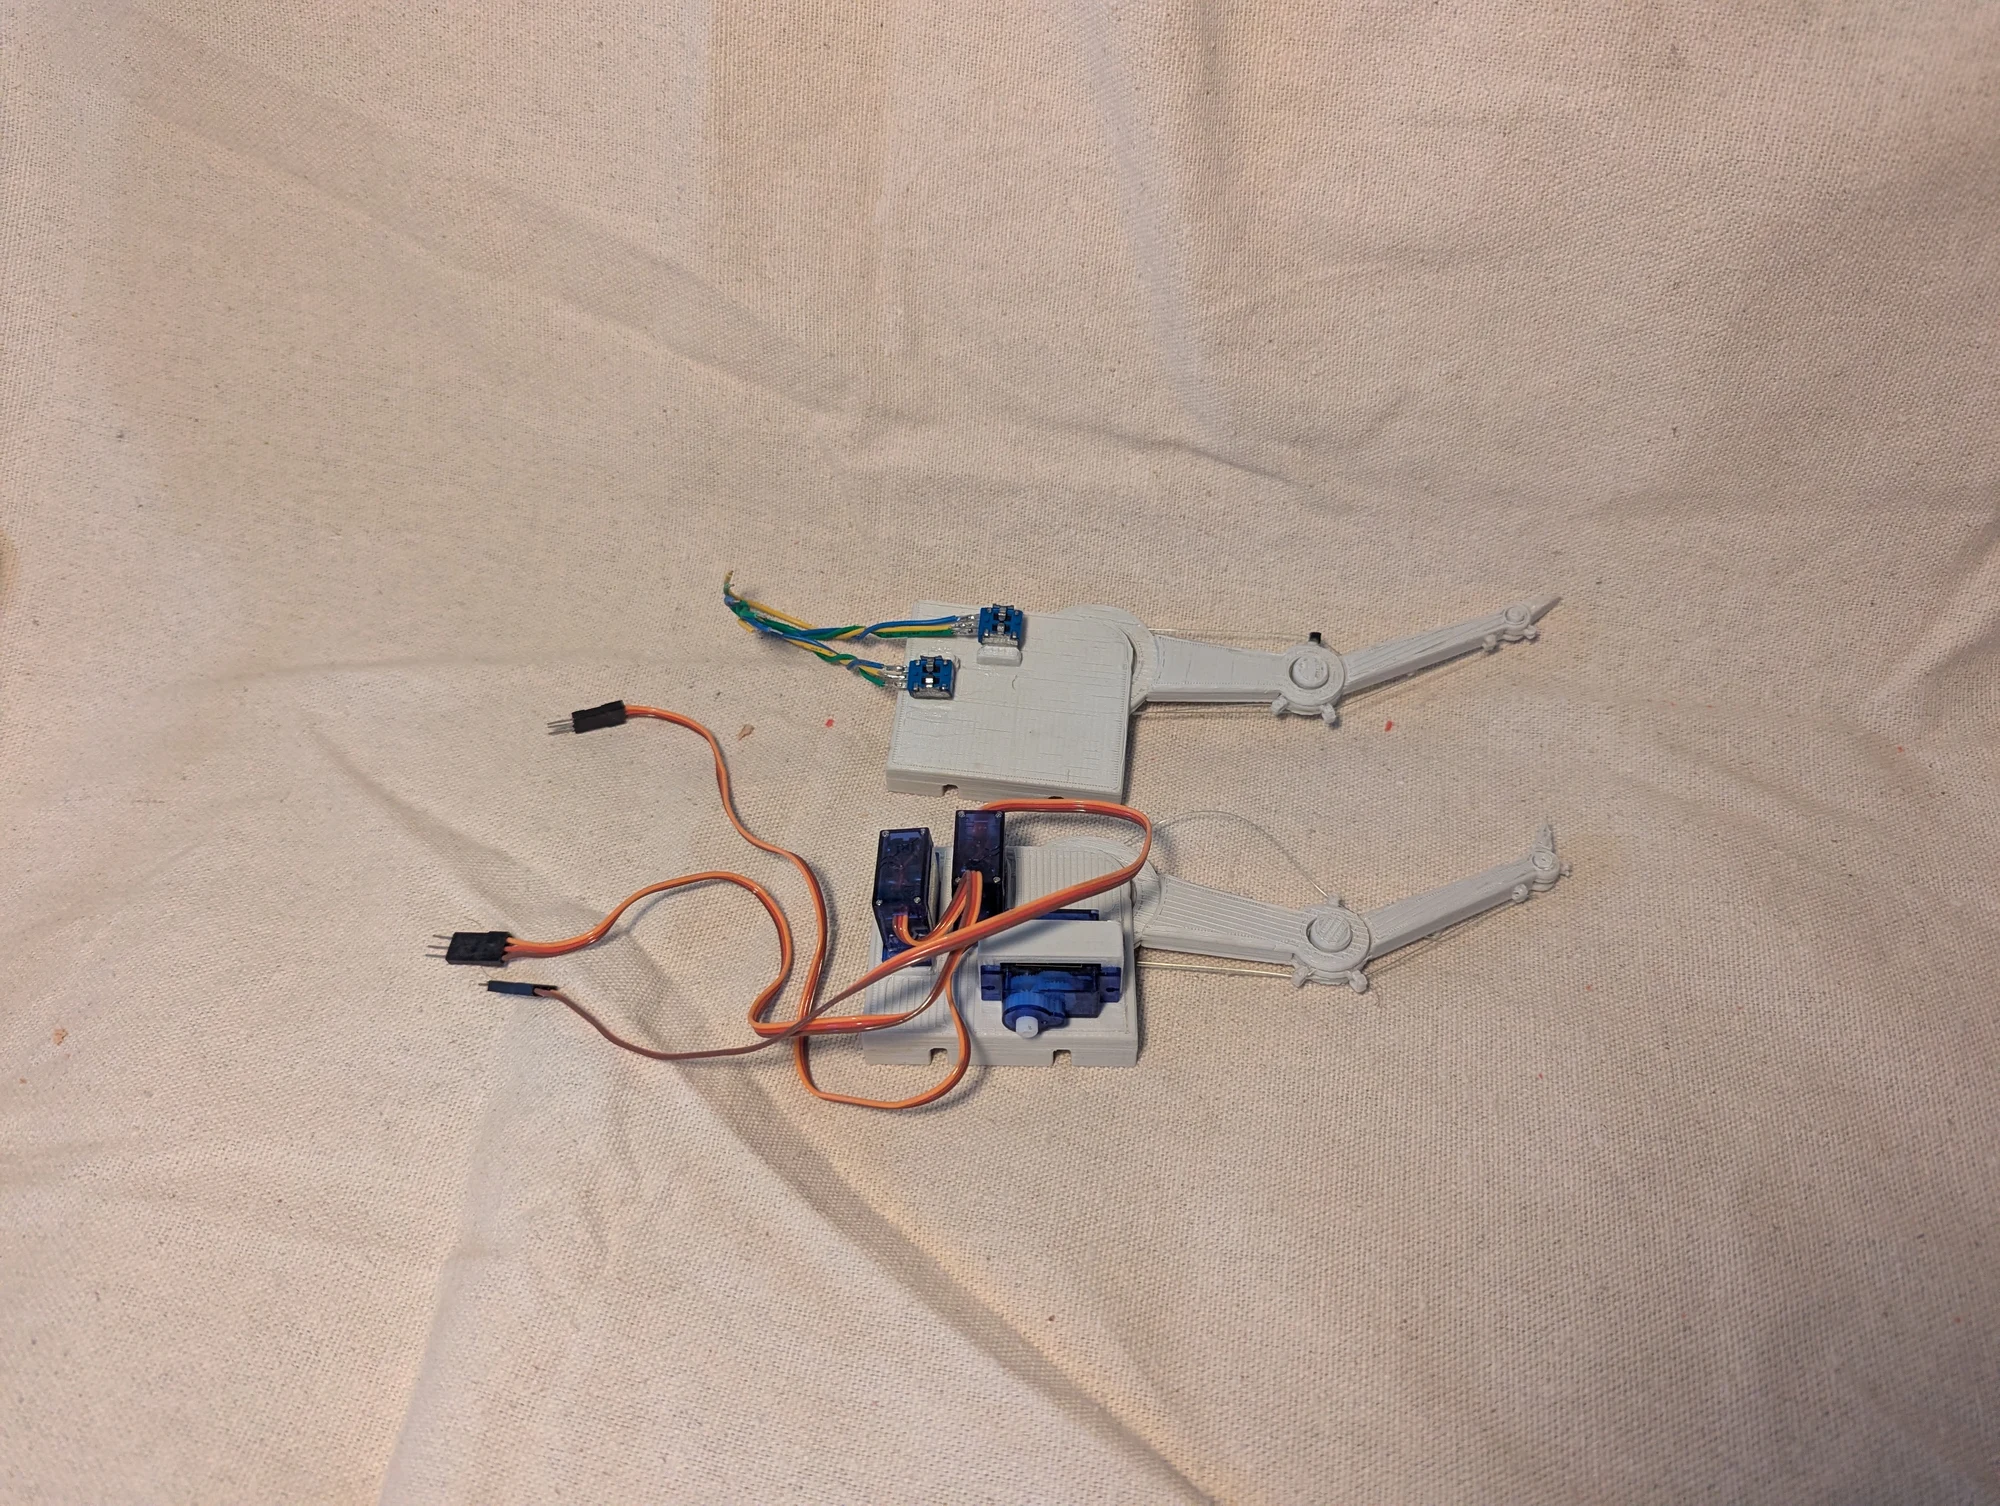
A rear view of the crab-leg robot prototype, showing the mechanism from the opposite side.
Iterations and component experiments
Photos 441–442
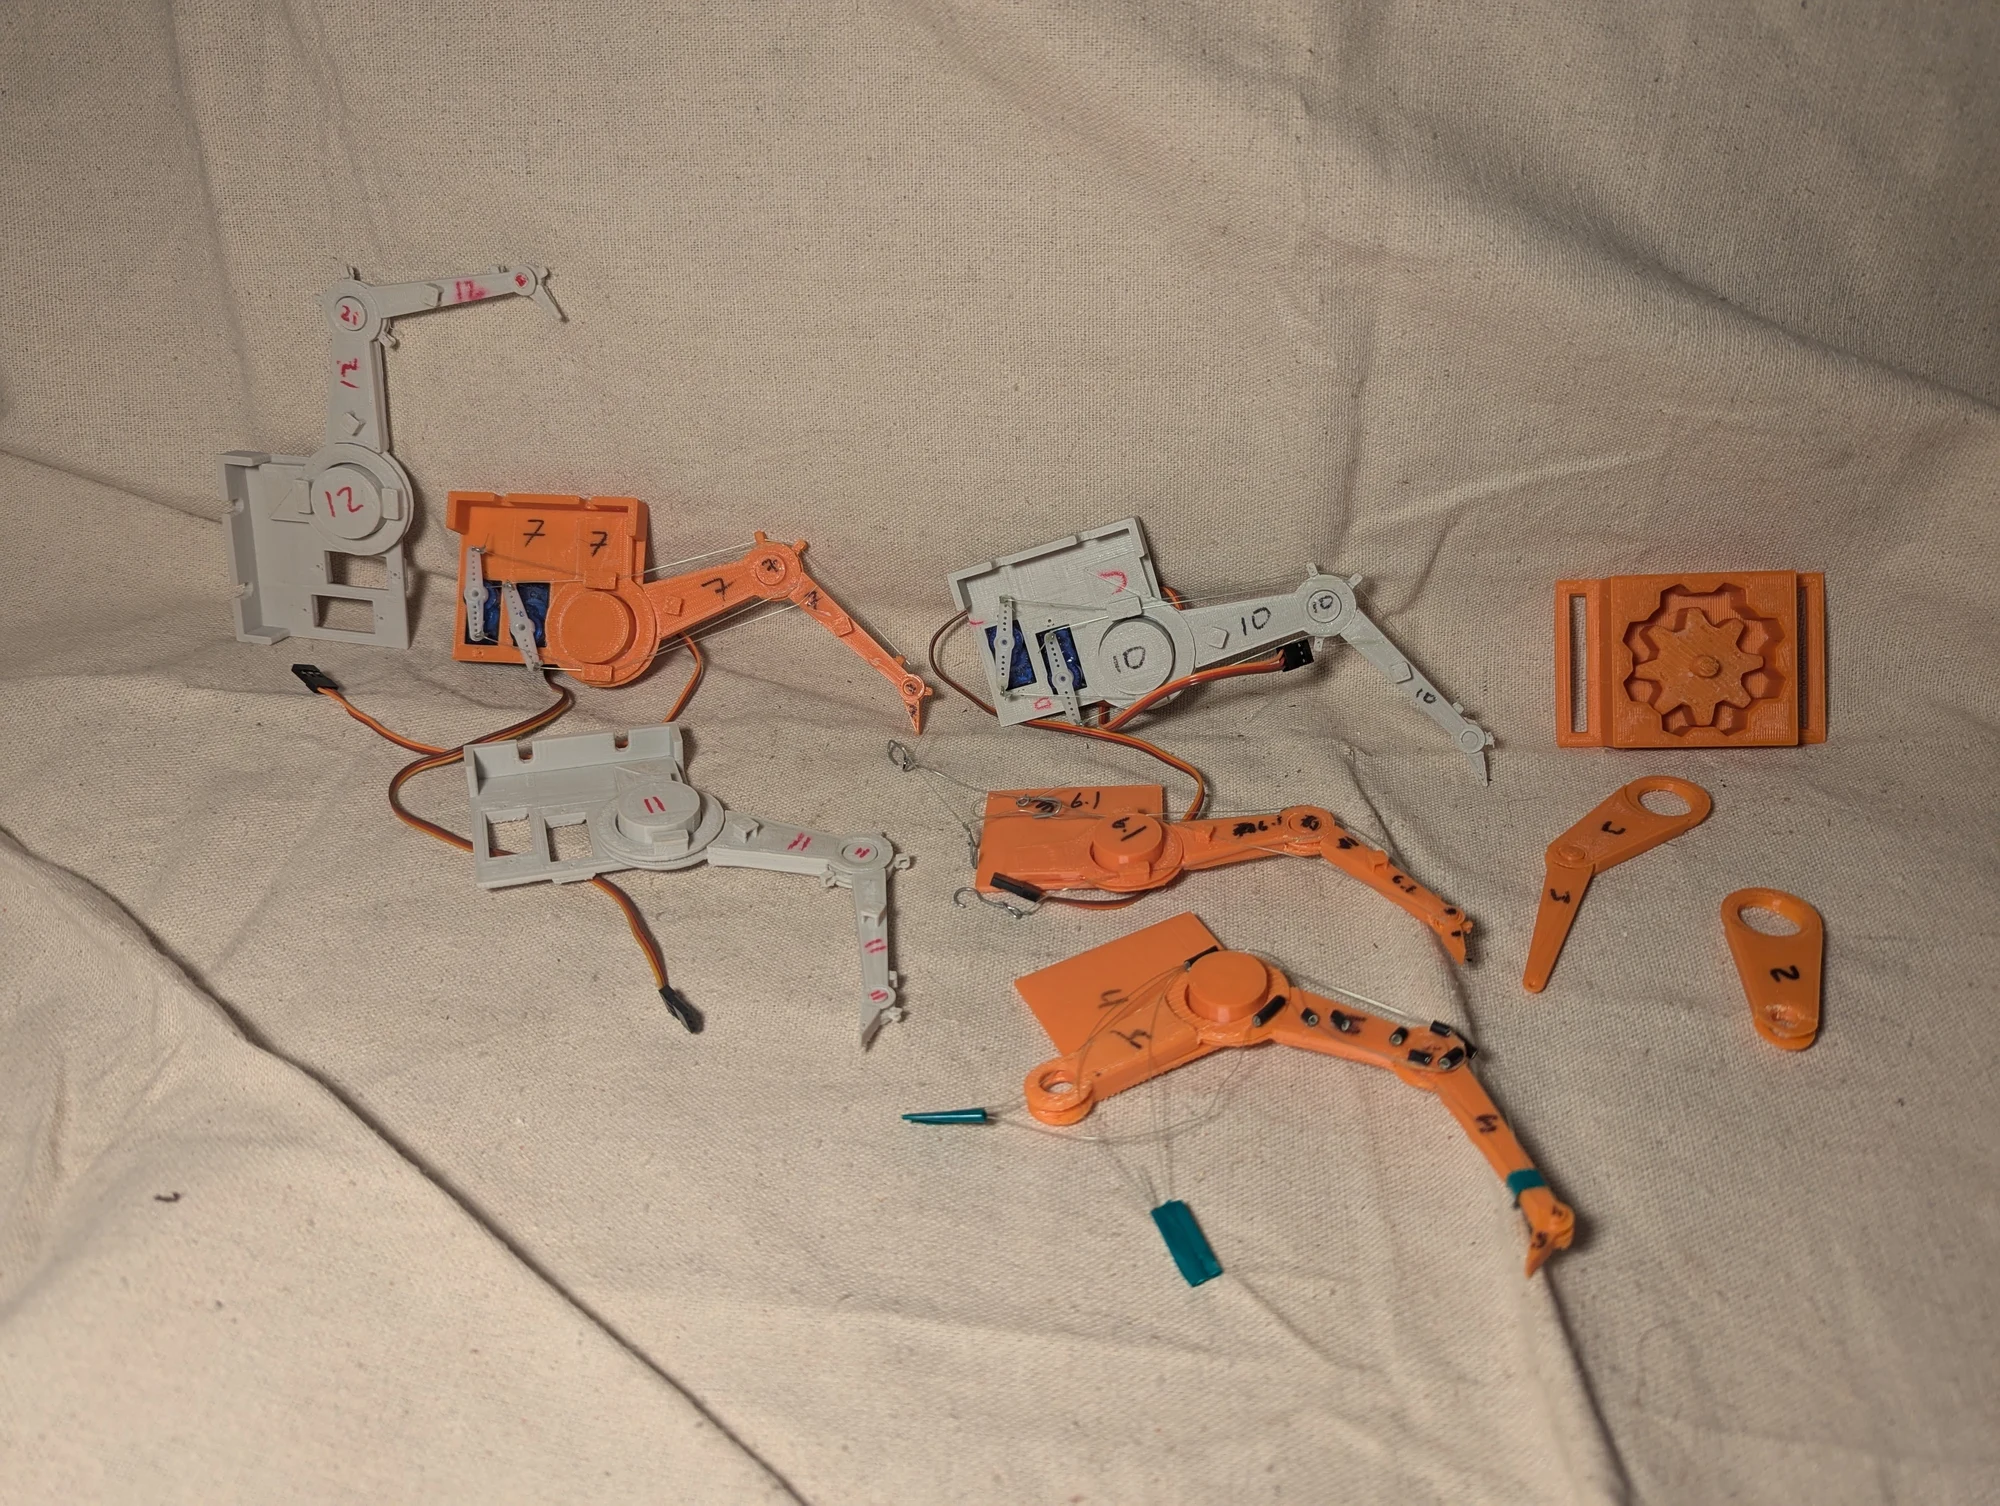
A collection of prototypes from my robotic crab-leg project, showing how the mechanism changed over many iterations. I also experimented with a wax-based mechanism intended to permit motion when the wax melted and hold a position when it solidified.
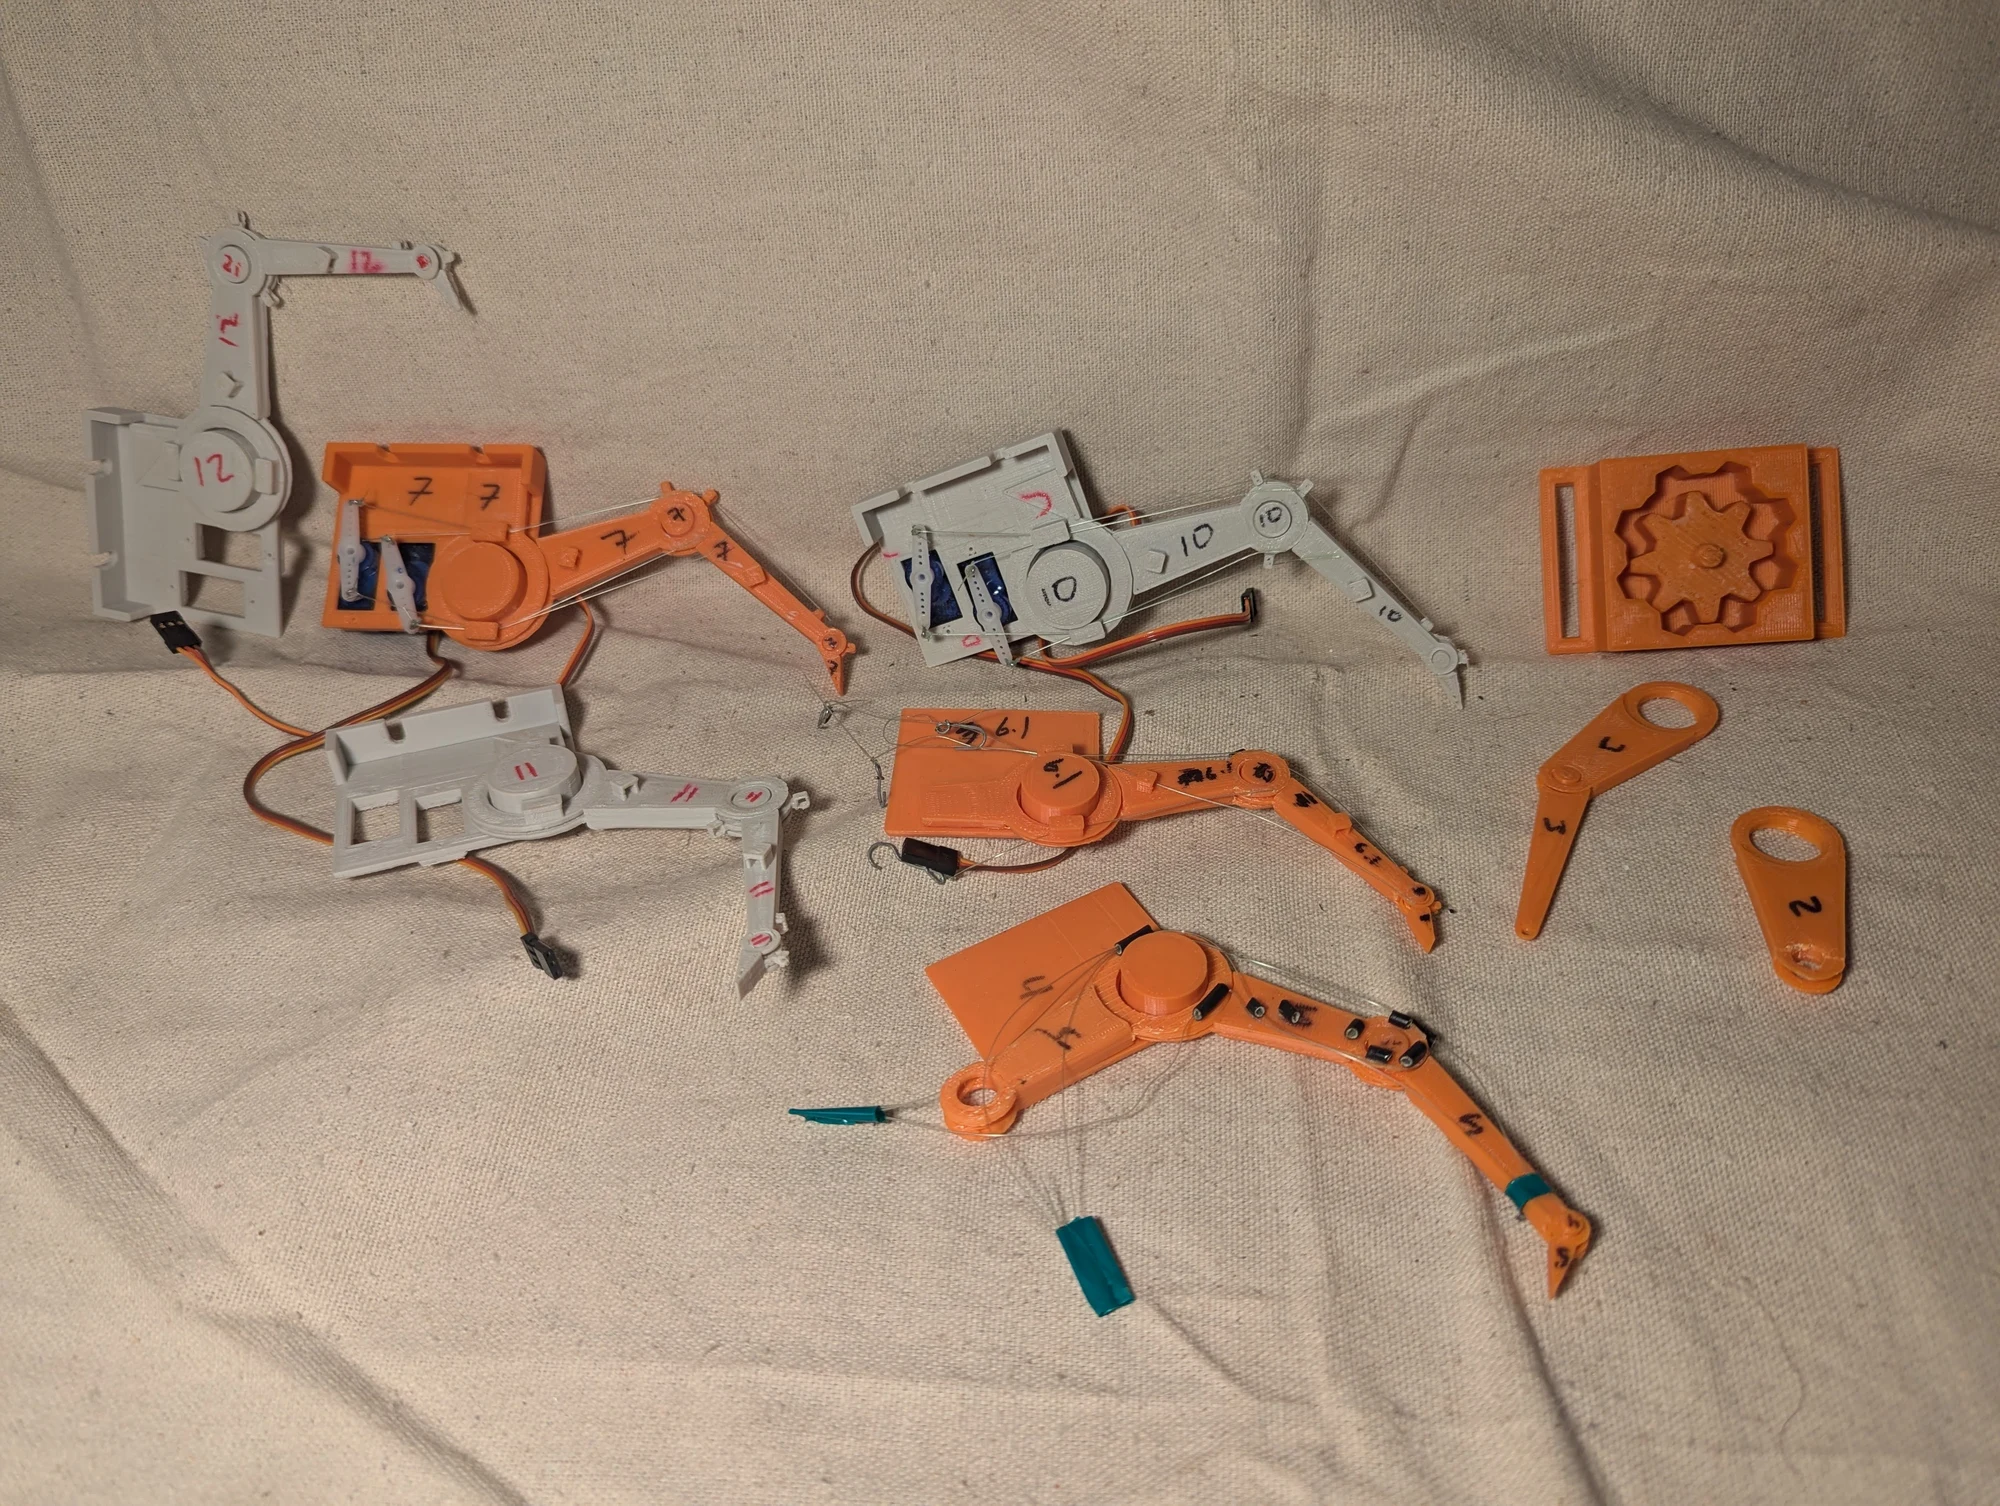
Another view of the collection of crab-leg mechanisms and related experiments. Making multiple versions let me explore different approaches to movement and joint control.